UIST 2026 RESEARCH PROJECT
Tap2Stop: Pedestrian-Activated Emergency Stop for Autonomous Vehicles
The 39th Annual ACM Symposium on User Interface Software and Technology · Detroit, MI, USA
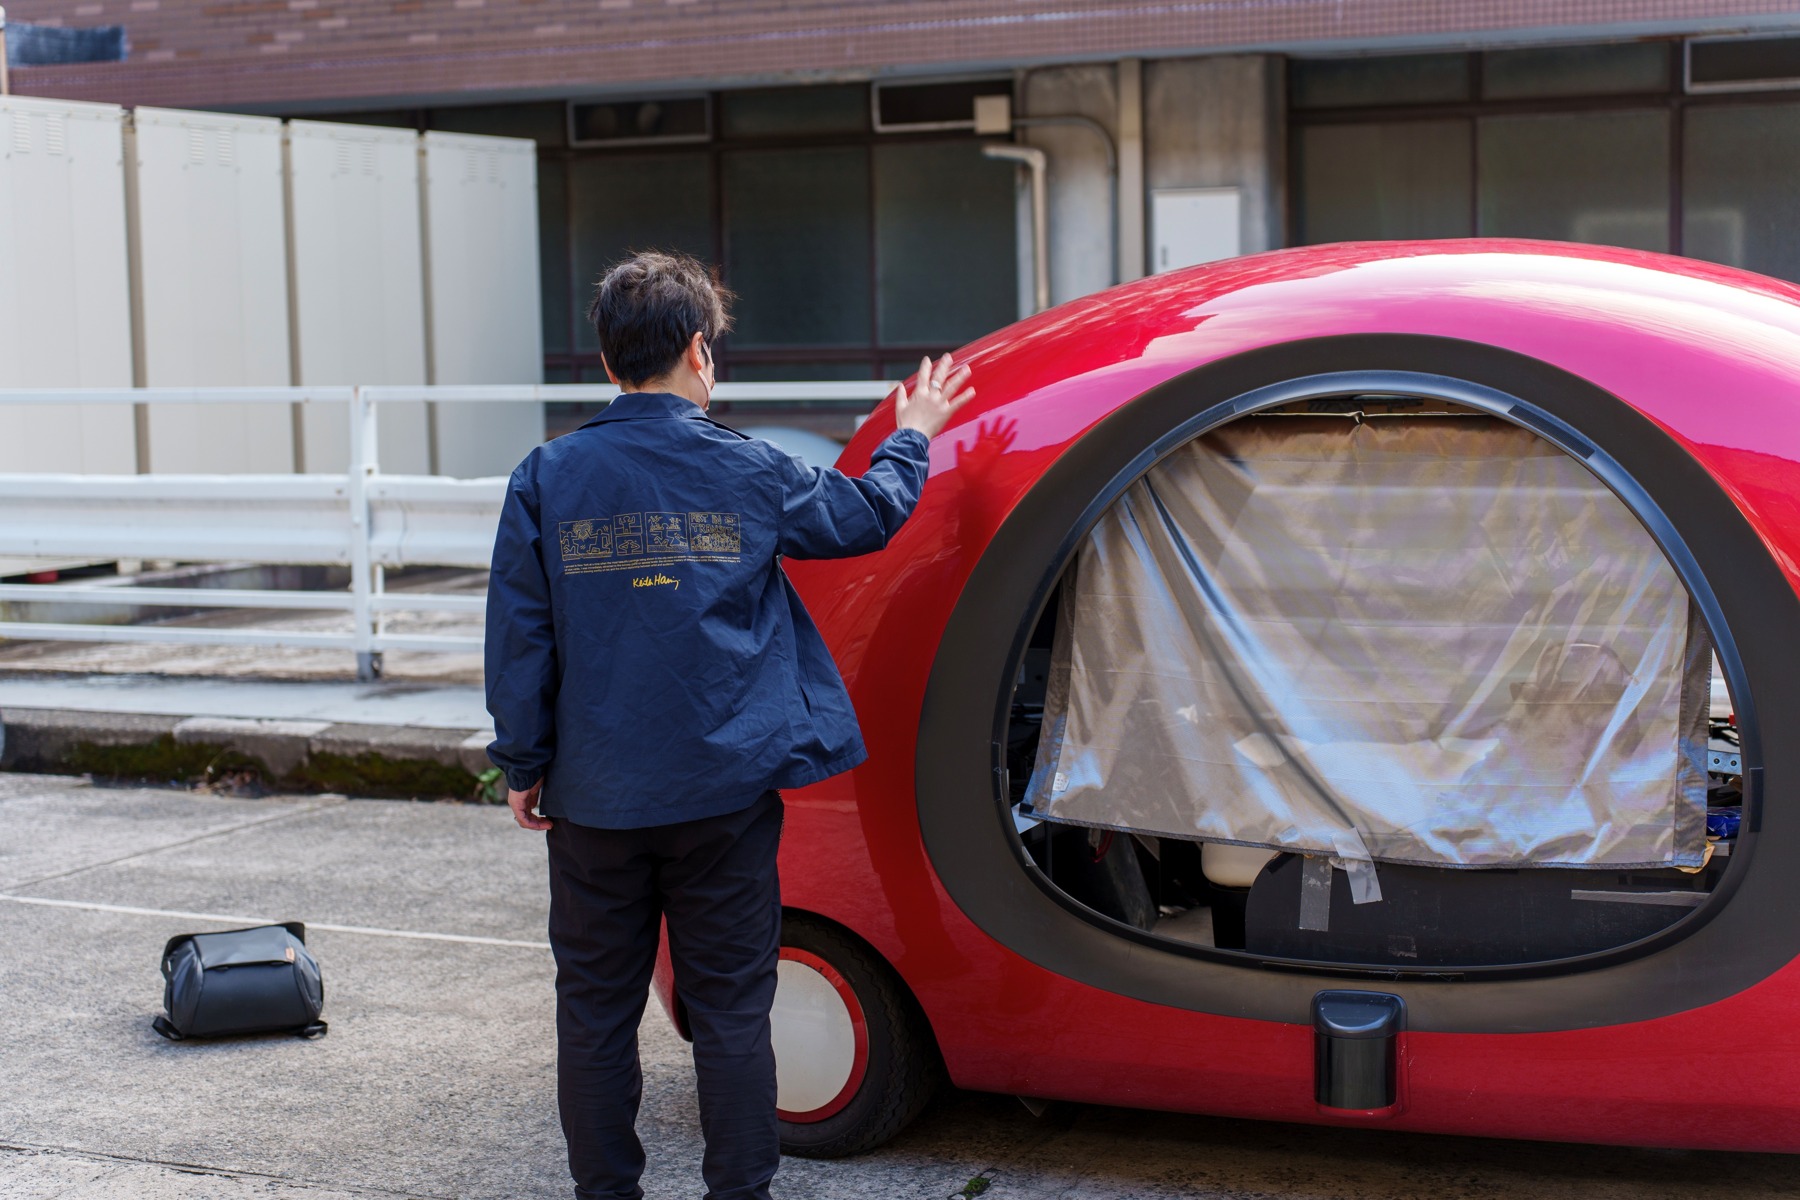 A TAP. A STOP. A WAY TO INTERVENE.
What if pedestrians could ask an autonomous vehicle to stop with a tap?
A physical intervention channel for close-range, low-speed situations.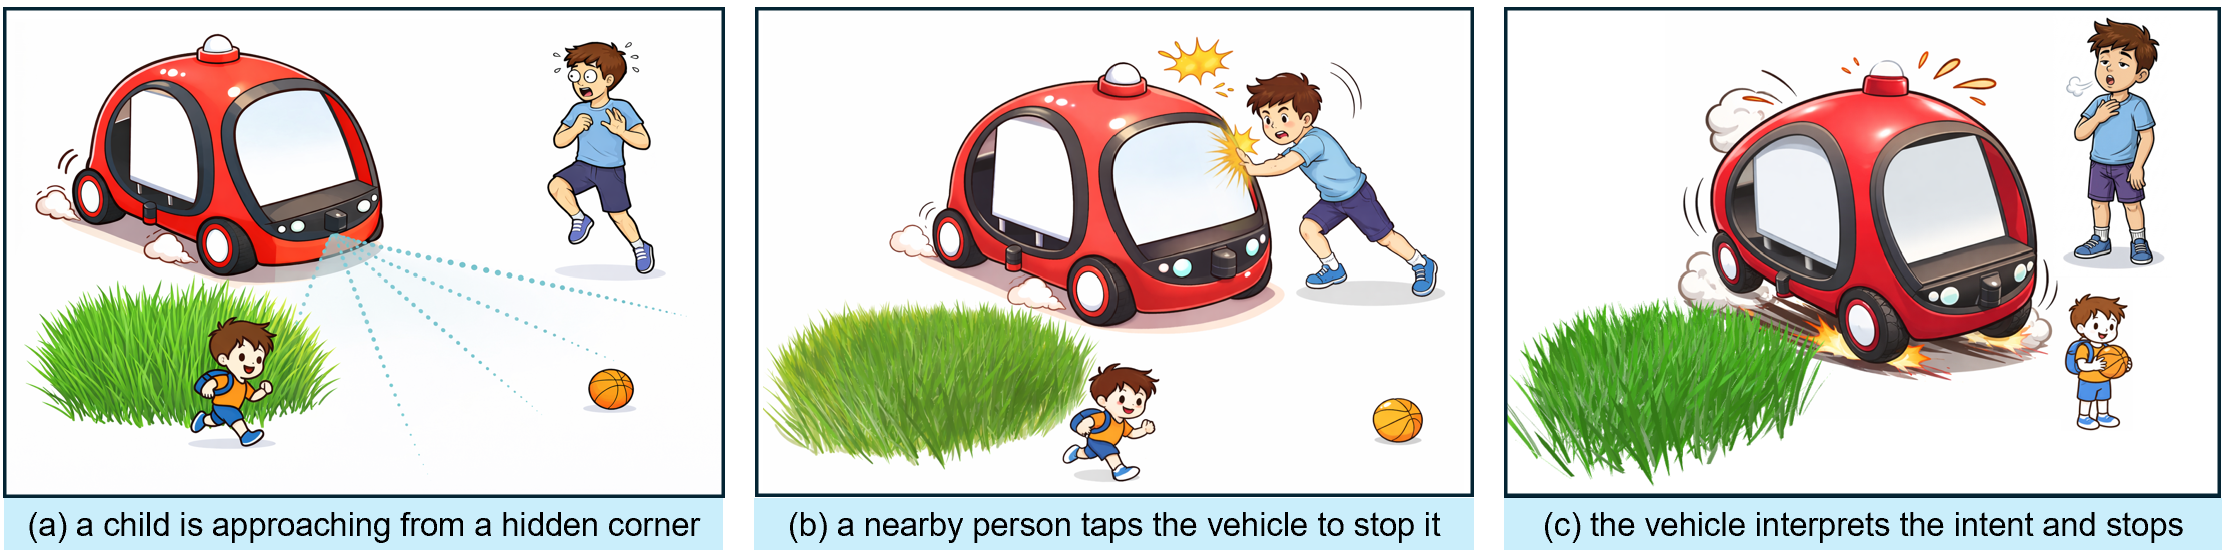
01 / RESEARCH
Abstract
Autonomous vehicles (AVs) remain imperfect in close-range interactions, where sensor blind spots and unpredictable pedestrian behavior lead to safety-critical failures. Existing emergency-stop mechanisms are typically limited to remote operators or passengers, leaving pedestrians unable to intervene. We propose Tap2Stop, an externally accessible mechanism that enables pedestrians to “actively” stop vehicles by tapping on the surface. A formative study (23 pedestrians, 8 AV developers) reveals a gap between pedestrians’ desire for intervention and developers’ concerns about misuse.
Guided by these insights, we develop a tapping-based system integrating two classifiers (tapping detection and intent classification) with a gating and accumulation mechanism to balance robustness and reaction time. Study 1 constructs a dataset across multiple conditions to train the classifiers and optimize parameters. Study 2 evaluates the system in a field study (N=18), showing promising performance (100% detection rate, 24% false positive rate), user acceptance, and providing insights for future bidirectional human-vehicle interaction.
Abstract and Figure 1 from the authors’ paper. Read the full study for the evaluation conditions and limitations. Paper licensed under CC BY 4.0.
02 / IN MOTION
See Tap2Stop in action.
A pedestrian taps. The vehicle responds.
The project’s vision video.
A research prototype exploring how nearby pedestrians can communicate a stop request directly to a vehicle. The interaction targets close-range, low-speed scenarios and was evaluated in a controlled field study.